We exhibited for the first time at the “2019 International Robot Exhibition (iREX 2019)” held at Tokyo Big Sight from December 18 (Wednesday) to 21 (Saturday), 2019. It was a huge success for us. In this article, we share an overview of what happened at the event.
We showed three of our products;
- Cloud Robotics Platform: rapyuta.io
- General-purpose controller for robotics arms (coming soon)
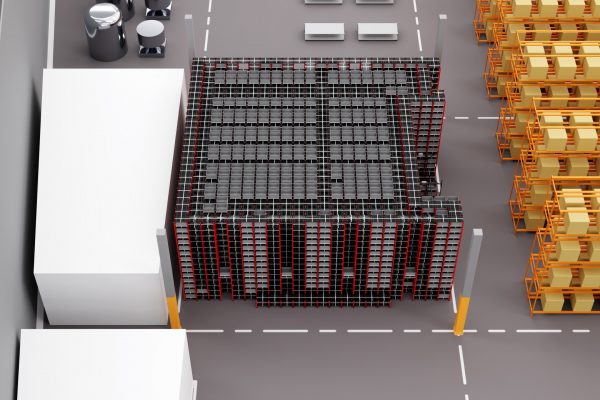
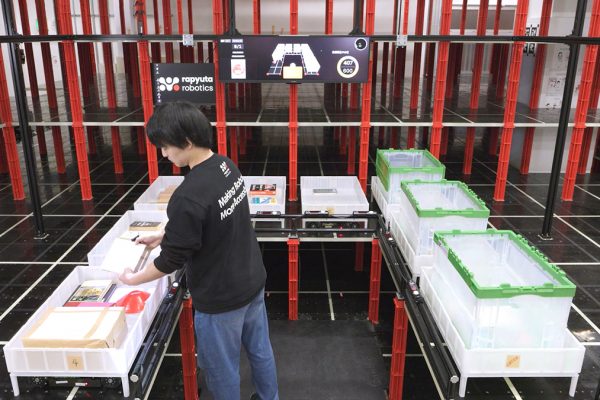
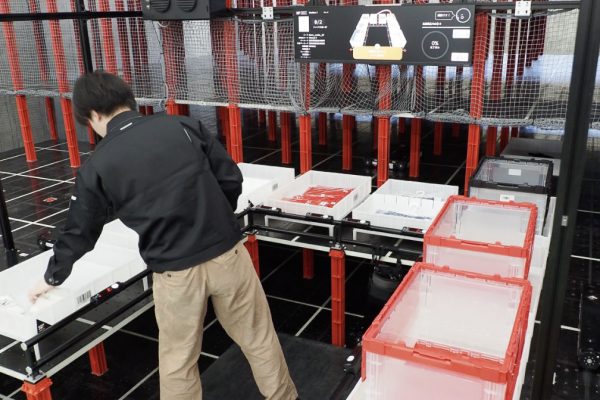
- Warehouse pick assist AMRs, Autonomous Mobile Robots
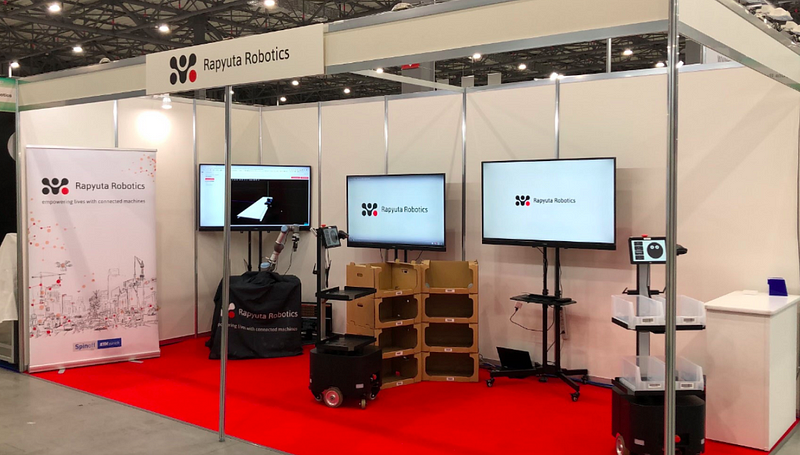
Lots of interest in ready-to-run AMR
We brought our next-generation AMR that was successfully tested with Nippon Express. When the visitors saw the actual product they had positive reviews. In particular, those who are in charge of small package logistics showed keen interest. In their own words, we quote:
“It is good to be able to operate without changing the layout of the warehouse.”
“It’s realistic with smooth collaboration between multiple AMRs and people.”
“The robots move faster than expected. It seems we can increase efficiency dramatically.”
This product is based on our cloud robotics platform — rapyuta.io, and we plan to expand its capabilities by connecting and letting it collaborate with other robots and automation equipment. Our solutions include other robotics including industrial arms and forklifts.
If you have any questions about collaborative picking robots or want to know more about what we do, we are happy to answer any time. Please contact us by filling the form: https://rapyuta-robotics.typeform.com/to/KdpD0Z
Browser-based simulation is a breakthrough
We have shown the robot arm controller and simulation software for the first time. We demonstrated writing a sample program on a browser and how to run it with a real machine. The following comments were received from those who actually saw it;
“It’s amazing that you can program using Python on a browser”
“Very good to work in a browser without installing the software locally”
“Good to have motion planning including collision avoidance in it”
When connected to the robot arm controller, it can be moved with the actual machine. It seemed that they were able to have a detailed image. As the product is currently in beta, we would like to hear your feedback on it to improve it.
If you’re interested in a demonstration of the robot arm control controller/simulation software or if you would want to learn more about what we do, please feel free to reach out via the contact form: https://rapyuta-robotics.typeform.com/to/KdpD0Z
We’re hiring!
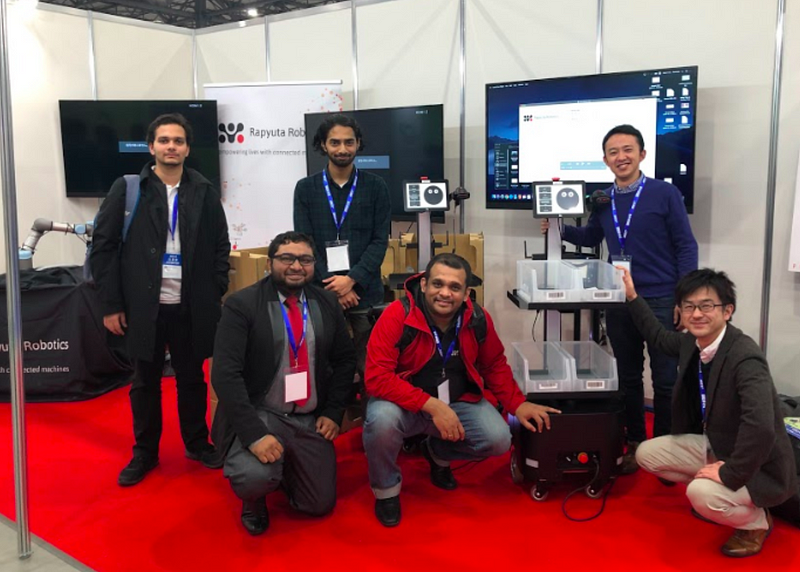
Some of them who visited the booth were interested in our work and company, such as students. We are rapidly growing. We are hiring for intern positions as well as full-time roles. Please visit our careers page to check out the open positions!