Blog /

ROS Noetic Support on rapyuta.io

Date: 15 Mar 2022
Category: Engineering

rapyuta.io platform now supports ROS Noetic – the 13th ROS distribution, exclusively targeted for Python3. ROS Noetic is primarily targeted for the Ubuntu Focal 20.04 release.

Working with ROS Noetic on rapyuta.io

Onboarding a Device

To onboard a device:

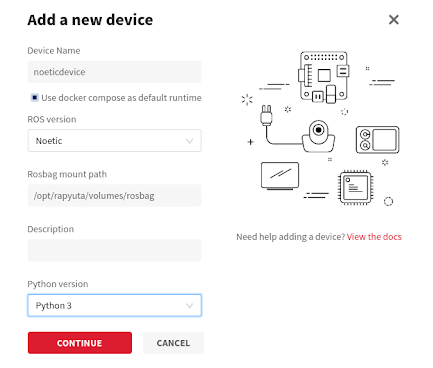
  1. On the left navigation bar, select Devices -> All Devices.
  2. Select ADD NEW DEVICE, enter the Device Name, and select Noetic from the ROS version dropdown menu.

For more information on onboarding a device, see Onboarding a Device.
Creating Builds

To create catkin builds for ROS Noetic:

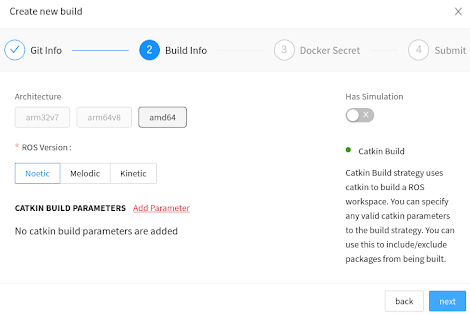
  1. On the left navigation bar, select Development -> Builds. 
  2. Select ADD NEW BUILD. 
  3. In the Create new build dialog, enter the Name, Repository, and select Catkin as the build recipe. Click next.
  4. Select Noetic as the ROS version.

For more information on creating builds, see Creating a Build.
Creating Packages

To create packages targeted for noetic deployments on the device or cloud:

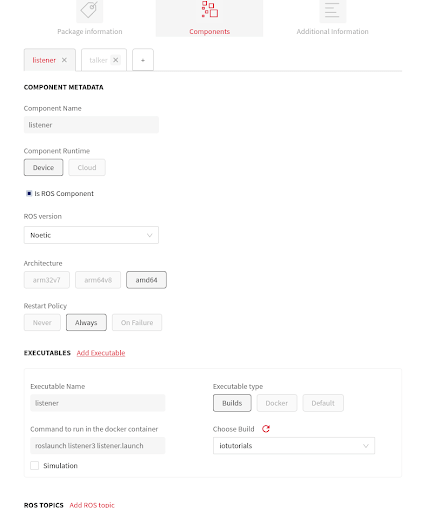
  1. On the left navigation bar, select Development -> Catalog. 
  2. Select ADD NEW PACKAGE, and enter the Package Name. Click next. 
  3. Enter the Component Name, select the Component Runtime, and select Noetic from the ROS version dropdown menu.

For more information on creating packages, see Creating Packages.
For further queries or support, please write to info@rapyuta-robotics.com.
Recent Articles

Strategic alliance names Numina Group as Rapyuta’s first U.S. systems integrator, bringing modular, scalable Goods-to-Person storage and picking technology to warehouse and manufacturing operations powered by Numina’s RDS™ WES-WCS platform. SCHAUMBURG, IL, November 13, 2026 (Newswire.com) – Rapyuta Robotics Inc., a pioneer in warehouse robotics headquartered in Tokyo, Japan, and Schaumburg, Illinois, and a leading […]

Abstract  Choosing an ASRS starts with understanding how your own operation behaves, not with comparing vendor spec sheets. Vendors publish throughput figures measured under conditions that will not match your operation. The gap between a rated number and a delivered one comes down to four things you can measure from an order file you already […]

Published: 2026-10-22 | Last updated: 2026-10-22 Statement Rapyuta Robotics products are not affected by PHP2Shell. No customer action is required. Overview PHP2Shell refers to two critical vulnerabilities in the PHP runtime. The PHP project released fixes on 2026-10-21. Rapyuta Robotics products and the systems deployed at customer sites do not use PHP. Some of our […]

Part 2 of 2. Read Part 1: ASRS Picking Station Design: Built for Operators, Orchestrated by Robots Part 1 of this series covered the Rapyuta ASRS picking station itself and why we designed it to put every bin within one step of the operator. A picking station only performs as well as the system that […]